With the amount of new subnets being added it can be hard to get up to date information across all subnets, so data may be slightly out of date from time to time
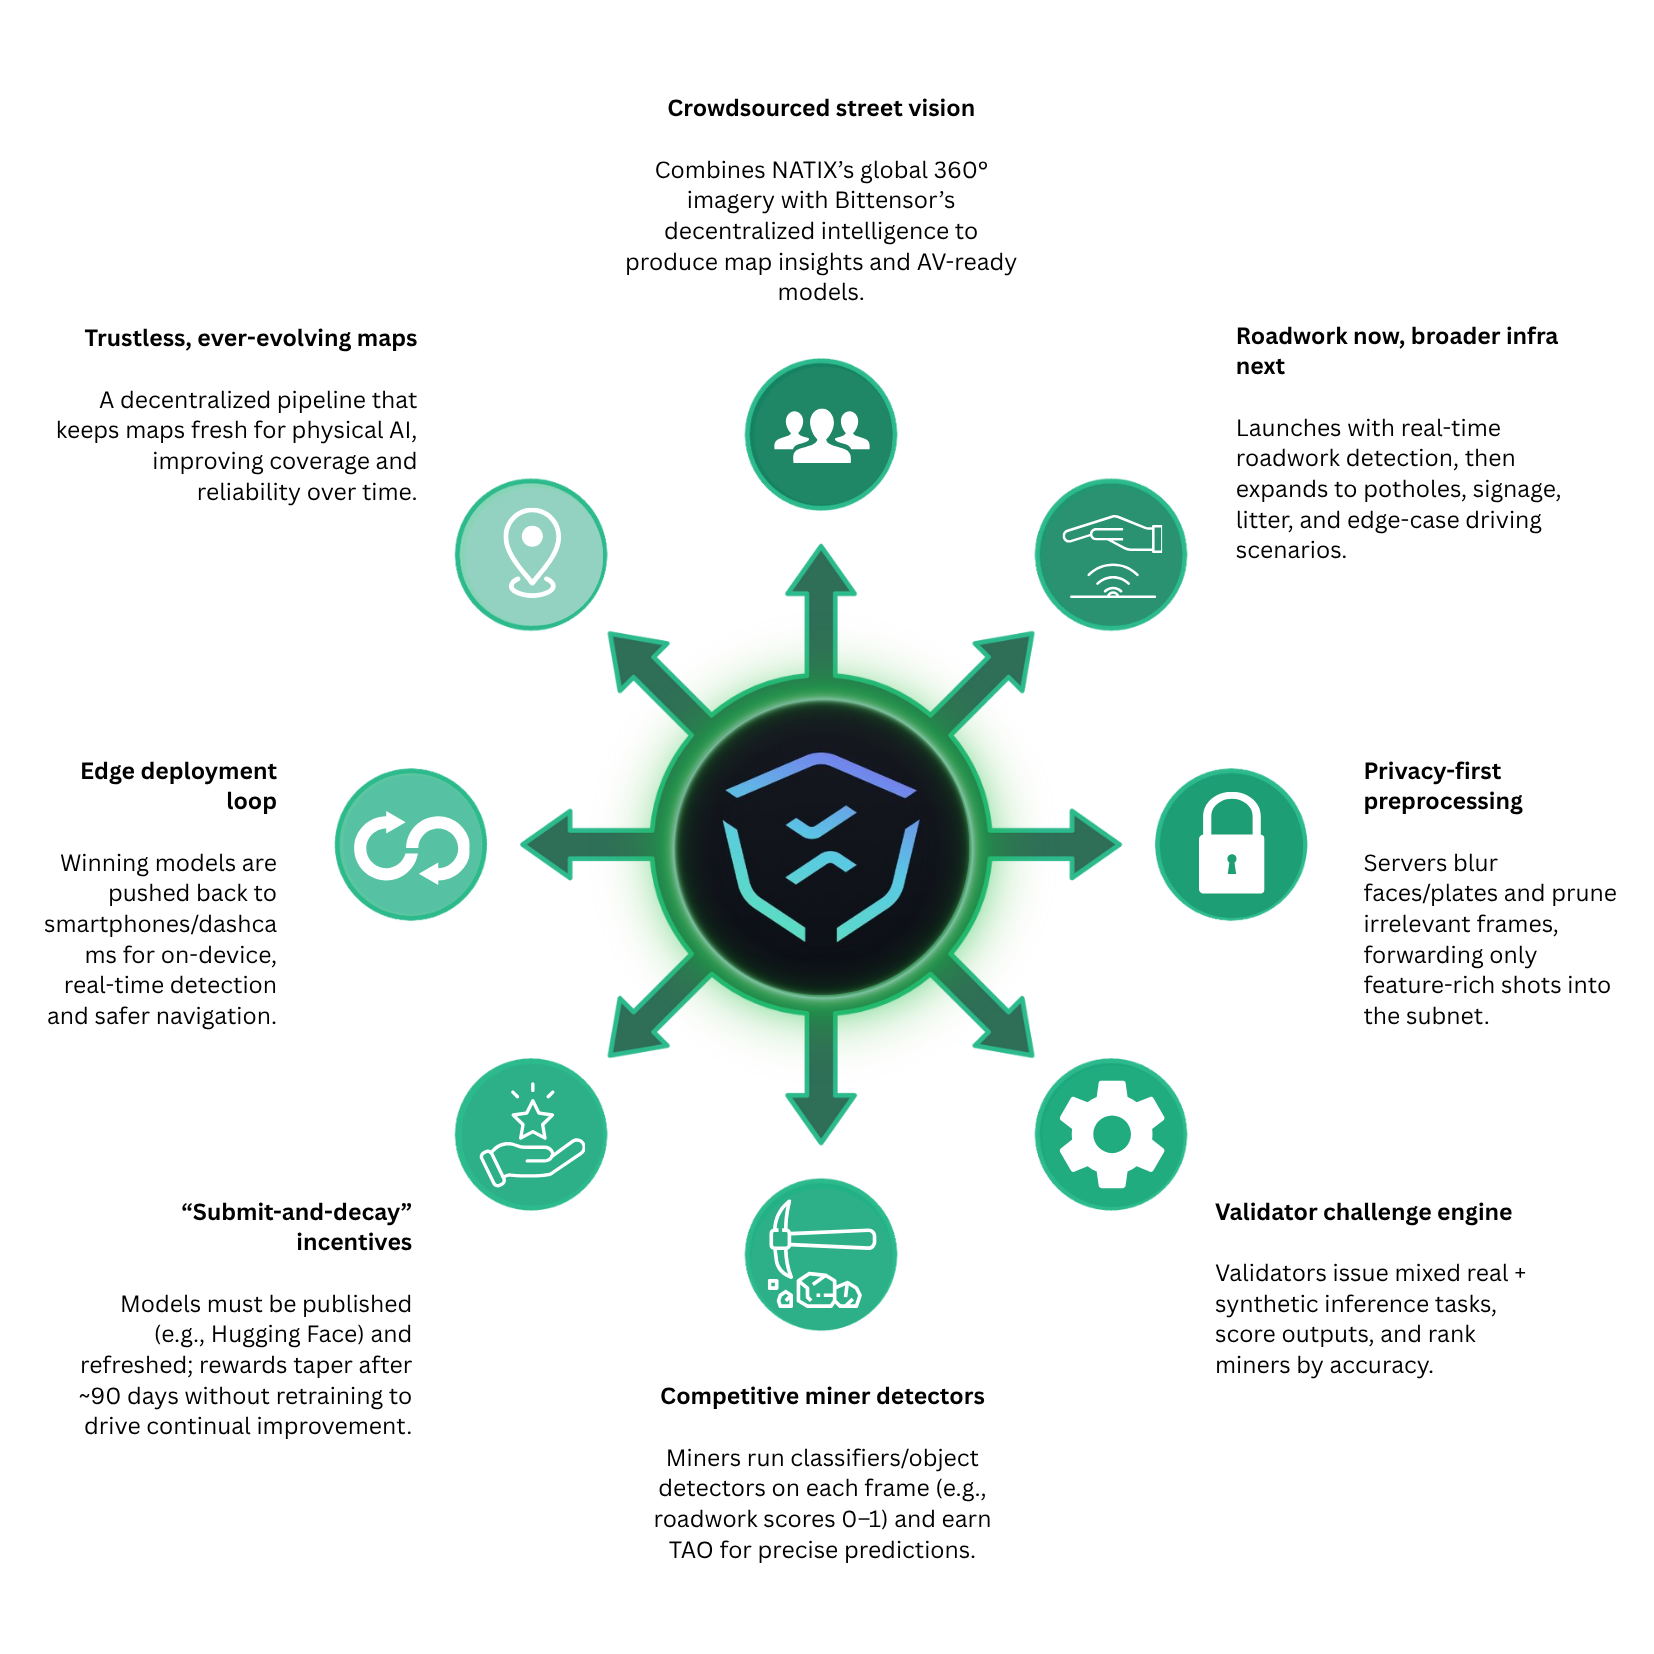
StreetVision is a specialized Bittensor subnet for analyzing crowdsourced street-level imagery to improve mapping and autonomous driving (Physical AI). It ingests 360° video and images from NATIX’s global camera network and outputs refined AI models and map insights. In NATIX’s words, StreetVision “combines NATIX’s curated real-world data with Bittensor’s crowdsourced intelligence” to create a “trustless, ever-evolving ecosystem” for autonomous vehicles and smart maps.
The initial focus is real-time roadwork detection (for navigation safety and map updates), but it will quickly expand to other infrastructure use cases (potholes, road signs, litter, etc.) and scenario classification (edge-case driving scenarios). As NATIX explains, StreetVision ingests live street imagery, continuously trains better models via miner competition, and feeds those models back to edge devices (smartphones/dashcams) for real-time analysis. In short, it uses decentralized AI to turn NATIX’s massive crowdsourced map data into actionable models for safer, more up-to-date maps and autonomous driving.
StreetVision is a specialized Bittensor subnet for analyzing crowdsourced street-level imagery to improve mapping and autonomous driving (Physical AI). It ingests 360° video and images from NATIX’s global camera network and outputs refined AI models and map insights. In NATIX’s words, StreetVision “combines NATIX’s curated real-world data with Bittensor’s crowdsourced intelligence” to create a “trustless, ever-evolving ecosystem” for autonomous vehicles and smart maps.
The initial focus is real-time roadwork detection (for navigation safety and map updates), but it will quickly expand to other infrastructure use cases (potholes, road signs, litter, etc.) and scenario classification (edge-case driving scenarios). As NATIX explains, StreetVision ingests live street imagery, continuously trains better models via miner competition, and feeds those models back to edge devices (smartphones/dashcams) for real-time analysis. In short, it uses decentralized AI to turn NATIX’s massive crowdsourced map data into actionable models for safer, more up-to-date maps and autonomous driving.
StreetVision follows a decentralized data pipeline on Bittensor with distinct roles for data ingestion, filtering, validators, and miners. In practice, NATIX’s system works as follows:
The subnet runs under Bittensor’s incentive model: it issues dTAO tokens each block (around 2 per block) shared by miners, validators, and NATIX as owner. Validators must stake NATIX tokens (and hold Alpha tokens) to participate; miners currently have no staking requirement to encourage wide participation. Together, this framework encourages a global community of miners and validators to build and refine the vision models while NATIX supplies the raw data.
Products and Applications
StreetVision sits atop NATIX’s DePIN platform of crowdsourced mapping. Key NATIX offerings feed into it:
StreetVision Platform: The subnet provides a backend AI service for smart mobility. Its applications include:
In essence, StreetVision is not a consumer app, but an AI platform: it processes NATIX’s live data to produce intelligent insights and models that feed back into NATIX’s ecosystem of apps and devices.
Architecture and Technical Details
Technically, StreetVision spans from edge hardware through Bittensor nodes:
Taken together, StreetVision is a physical-to-digital AI stack: real-world video → cloud preprocessing → Bittensor validators/miners → refined models → edge inference.
StreetVision follows a decentralized data pipeline on Bittensor with distinct roles for data ingestion, filtering, validators, and miners. In practice, NATIX’s system works as follows:
The subnet runs under Bittensor’s incentive model: it issues dTAO tokens each block (around 2 per block) shared by miners, validators, and NATIX as owner. Validators must stake NATIX tokens (and hold Alpha tokens) to participate; miners currently have no staking requirement to encourage wide participation. Together, this framework encourages a global community of miners and validators to build and refine the vision models while NATIX supplies the raw data.
Products and Applications
StreetVision sits atop NATIX’s DePIN platform of crowdsourced mapping. Key NATIX offerings feed into it:
StreetVision Platform: The subnet provides a backend AI service for smart mobility. Its applications include:
In essence, StreetVision is not a consumer app, but an AI platform: it processes NATIX’s live data to produce intelligent insights and models that feed back into NATIX’s ecosystem of apps and devices.
Architecture and Technical Details
Technically, StreetVision spans from edge hardware through Bittensor nodes:
Taken together, StreetVision is a physical-to-digital AI stack: real-world video → cloud preprocessing → Bittensor validators/miners → refined models → edge inference.
NATIX is led by its founding team, supported by strategic partners in AI and mobility:
Alireza Ghods, Ph.D. – Co-founder & CEO of NATIX. (10+ years in IoT, mapping, autonomous driving).
Lorenz Muck – Co-founder & CPO. (VR/Computer Vision product expert).
Omid Mogharian – Co-founder & CTO. (15+ years in software and blockchain).
Dr. Ulrich Lages – Core contributor (Automotive Lead). (LiDAR pioneer with 30+ years in AI/AV).
Partnering organizations:
Yuma (DCG) – An AI infrastructure company incubated by Digital Currency Group. Yuma guided StreetVision’s launch, contributing AI modeling and go-to-market support. (Yuma is explicitly credited for incubating Subnet 72.)
BitMind – Open-source AI architecture (cited as inspiration for the subnet).
Grab – Southeast Asian tech “super-app”; collaborated on the VX360 hardware. Grab is also an early customer (using NATIX data for maps).
Solana Labs – Underlying blockchain (NATIX runs on Solana).
Bittensor Foundation – The core decentralized AI network. (Subnet is part of Bittensor’s ecosystem; validators are part of Bittensor community).
These affiliations and personnel are publicly verifiable from NATIX’s site and press. For instance, NATIX’s “About” page lists the founders and core contributors, and the StreetVision announcement explicitly names Yuma/DCG involvement and Grab’s role.
NATIX is led by its founding team, supported by strategic partners in AI and mobility:
Alireza Ghods, Ph.D. – Co-founder & CEO of NATIX. (10+ years in IoT, mapping, autonomous driving).
Lorenz Muck – Co-founder & CPO. (VR/Computer Vision product expert).
Omid Mogharian – Co-founder & CTO. (15+ years in software and blockchain).
Dr. Ulrich Lages – Core contributor (Automotive Lead). (LiDAR pioneer with 30+ years in AI/AV).
Partnering organizations:
Yuma (DCG) – An AI infrastructure company incubated by Digital Currency Group. Yuma guided StreetVision’s launch, contributing AI modeling and go-to-market support. (Yuma is explicitly credited for incubating Subnet 72.)
BitMind – Open-source AI architecture (cited as inspiration for the subnet).
Grab – Southeast Asian tech “super-app”; collaborated on the VX360 hardware. Grab is also an early customer (using NATIX data for maps).
Solana Labs – Underlying blockchain (NATIX runs on Solana).
Bittensor Foundation – The core decentralized AI network. (Subnet is part of Bittensor’s ecosystem; validators are part of Bittensor community).
These affiliations and personnel are publicly verifiable from NATIX’s site and press. For instance, NATIX’s “About” page lists the founders and core contributors, and the StreetVision announcement explicitly names Yuma/DCG involvement and Grab’s role.
2020: NATIX Network founded (Hamburg); launched Drive& app to crowdsource mapping data.
2023–2024: 250K+ drivers joined; the network mapped 170M+ km of roads. Platform matured to include wearable/automotive devices.
Nov 2024: Launched the VX360 Tesla camera device and companion app. Secured first enterprise data client (large geospatial firm). Burned 33M+ $NATIX tokens as part of tokenomics. Achieved a “Network Laps” milestone of 100M km, rewarding users.
Q1 2025: Network grew to ~244K users and ~153M km mapped. NATIX relaunched its Network Laps V2 reward program and burned another 38M+ $NATIX. New partnerships announced (e.g. with E-Money, RepairPal).
May 2025: StreetVision Subnet (Subnet 72) launched on Bittensor. This marked the beginning of on-chain training of the roadwork-detection model. Initial tasks (roadwork classification) went live to test the system.
Current (mid-2025): StreetVision is processing NATIX’s live data feeds. Grab is a paying customer already integrating NATIX data. The team is adding validators and encouraging miners (now open without staking requirements). Several autonomous-driving companies are in talks to use the data/models. NATIX holds regular updates (monthly “Progress” blogs and AMAs) hinting at big announcements ahead.
Upcoming: The subnet will broaden its scope. As NATIX and its press note, next targets include pothole detection, sign recognition, litter identification, and infrastructure monitoring. They will also enable scenario classification of driving videos for AV simulation. In parallel, NATIX plans to monetize these models and insights (via protocol revenue) to support token value. Technical enhancements like model updates on Hugging Face and further decentralization (more validators) are ongoing. Finally, NATIX is working with top AV research labs to deliver “simulation-to-reality” products in the coming months.
Milestones to watch: deployment of production-grade roadwork models, rollout of additional use-cases (potholes, etc.), and any official partnerships with autonomous vehicle or mapping firms. NATIX’s public communications (blog and social media) regularly outline these plans, which align with their vision of a continuously improving, decentralized street-vision AI network.
2020: NATIX Network founded (Hamburg); launched Drive& app to crowdsource mapping data.
2023–2024: 250K+ drivers joined; the network mapped 170M+ km of roads. Platform matured to include wearable/automotive devices.
Nov 2024: Launched the VX360 Tesla camera device and companion app. Secured first enterprise data client (large geospatial firm). Burned 33M+ $NATIX tokens as part of tokenomics. Achieved a “Network Laps” milestone of 100M km, rewarding users.
Q1 2025: Network grew to ~244K users and ~153M km mapped. NATIX relaunched its Network Laps V2 reward program and burned another 38M+ $NATIX. New partnerships announced (e.g. with E-Money, RepairPal).
May 2025: StreetVision Subnet (Subnet 72) launched on Bittensor. This marked the beginning of on-chain training of the roadwork-detection model. Initial tasks (roadwork classification) went live to test the system.
Current (mid-2025): StreetVision is processing NATIX’s live data feeds. Grab is a paying customer already integrating NATIX data. The team is adding validators and encouraging miners (now open without staking requirements). Several autonomous-driving companies are in talks to use the data/models. NATIX holds regular updates (monthly “Progress” blogs and AMAs) hinting at big announcements ahead.
Upcoming: The subnet will broaden its scope. As NATIX and its press note, next targets include pothole detection, sign recognition, litter identification, and infrastructure monitoring. They will also enable scenario classification of driving videos for AV simulation. In parallel, NATIX plans to monetize these models and insights (via protocol revenue) to support token value. Technical enhancements like model updates on Hugging Face and further decentralization (more validators) are ongoing. Finally, NATIX is working with top AV research labs to deliver “simulation-to-reality” products in the coming months.
Milestones to watch: deployment of production-grade roadwork models, rollout of additional use-cases (potholes, etc.), and any official partnerships with autonomous vehicle or mapping firms. NATIX’s public communications (blog and social media) regularly outline these plans, which align with their vision of a continuously improving, decentralized street-vision AI network.
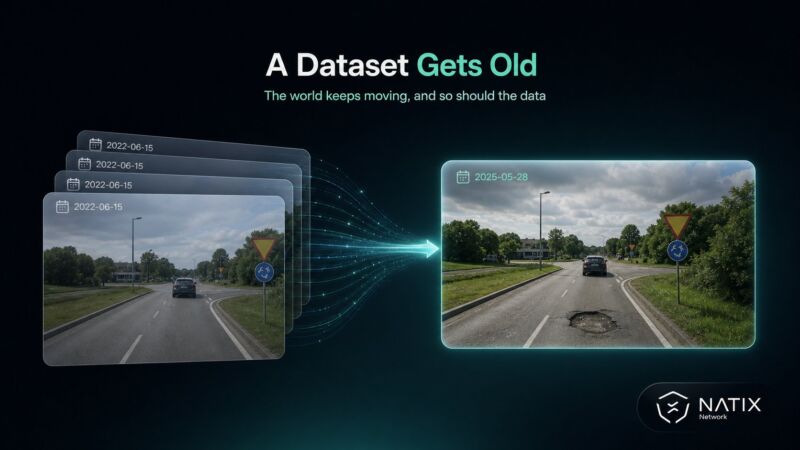
Data is a magic word that is used a lot, as if it can solve all the problems in the world.
But data gets old, and the datasets that come with it are often out of date.
A data engine keeps the data fresh and constantly updated. That's the NATIX way 💪
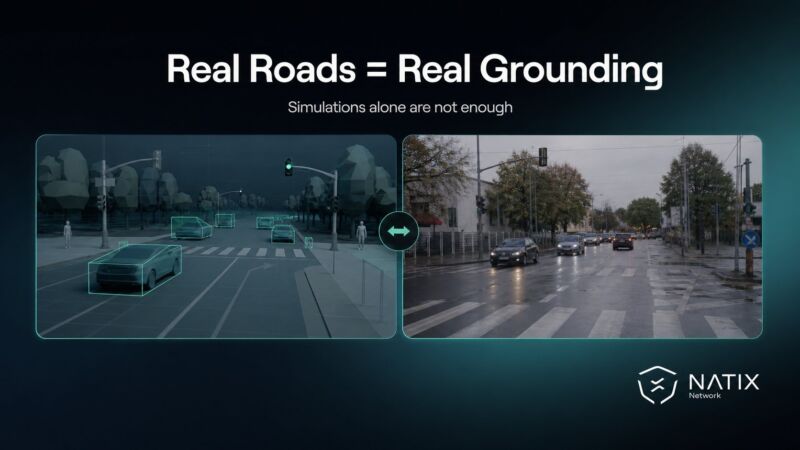
If you let an AI try to imagine how a vehicle would behave in real life, it would start hallucinating real fast. 😵💫
That's what the real-world data collected by NATIX can prevent.
Real roads = Simulations based on real life. 🌎
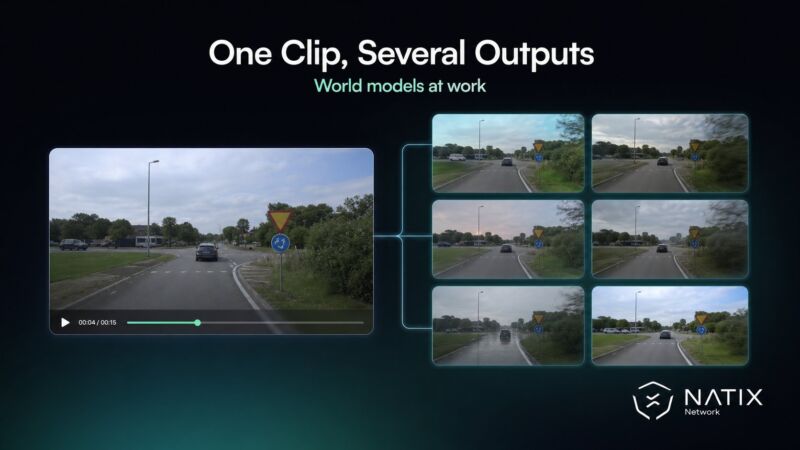
World Models don't just replicate a scenario, they take one scene and can simulate every possible outcome. 🤖
However, for a World Model to do that successfully, it needs real-world data to learn from, so the outputs are grounded in reality.
It all starts with quality data 🌐
Physical AI means more than just autonomous driving.
Robots will become a big part of our future, and the real-world data we collect at NATIX is no less important for their training.
If you wish to read more about it, we've got you covered 👇
Physical AI Beyond Cars: How Driving Data Trains Robots
Autonomous driving has built the largest training corpus of the physical world. Here is how that data is now training the next generation of robots.
www.natix.network
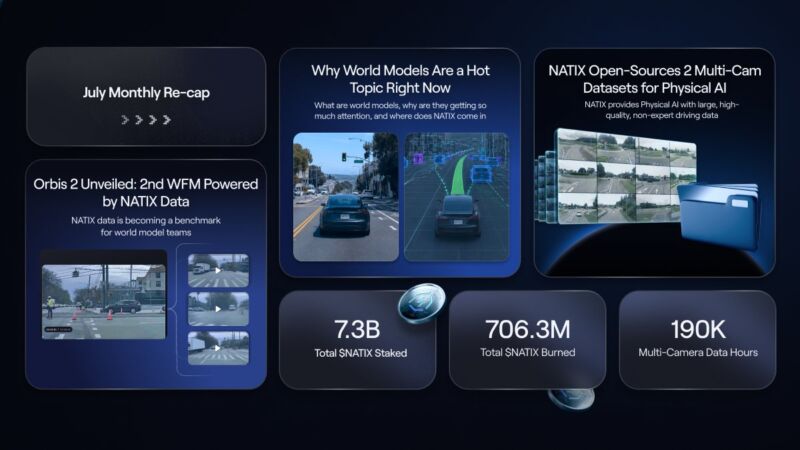
Our July Progress Update just dropped:
📹>190K Hours of Multi-Camera Footage
💹>7.3B $NATIX Staked
🌐Orbis 2 unveiled: 2nd World Model powered by NATIX data
📂Two multi-cam datasets open-sourced on @huggingface
🔥Why World Models are hot right now
Full recap👇
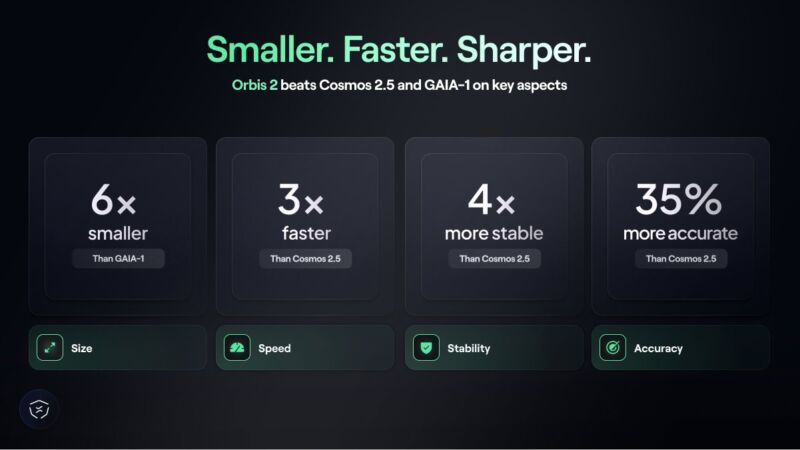
Orbis 2, a leading World Model built primarily on NATIX data, outperformed several other world-leading models, despite being smaller and trained on less data.
If that's not a sign that quality, real-world data makes a difference, we're not sure what would convince you.